UMS CVPR 2026
Unsupervised Multi-agent and Single-agent Perception from Cooperative Views
At the Physical AI Lab, we develop robust, efficient, and generalizable Physical AI systems that perceive, plan, learn, and act in the physical world. Our research spans autonomous driving, V2X, robotics, computer vision, machine learning, large language models, edge AI, and interdisciplinary applications across transportation, agriculture, and other real-world domains.
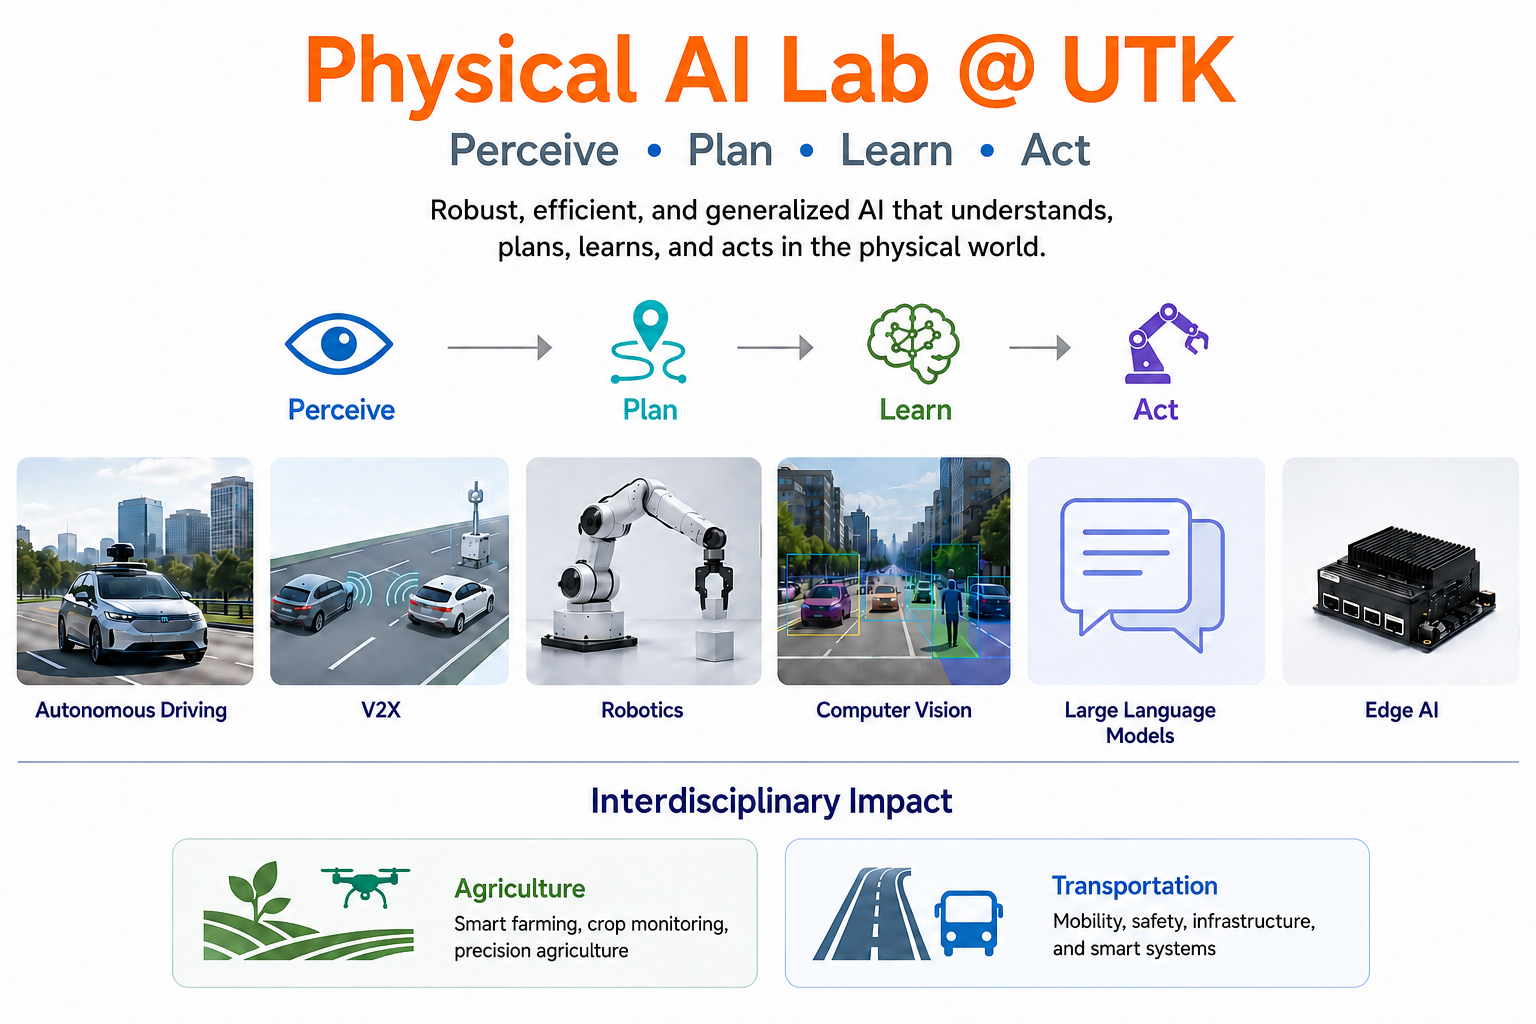
Perception, motion planning, V2X intelligence, world model, large language models
Perceive, plan, manipulate, and act reliably in dynamic environments, VLA
Detection, recognition, perception under challenging conditions
Transfer learning, domain generalization, unsupervised learning, trustworthy AI
Unsupervised Multi-agent and Single-agent Perception from Cooperative Views
V2X-DGW: Domain Generalization for Multi-Agent Perception Under Adverse Weather Conditions
Light the Night: A Multi-Condition Diffusion Framework for Unpaired Low-Light Enhancement in Autonomous Driving
V2V4Real: A large-scale real-world dataset for Vehicle-to-Vehicle Cooperative Perception